After background rotation and estimated aircraft maneuvers are removed
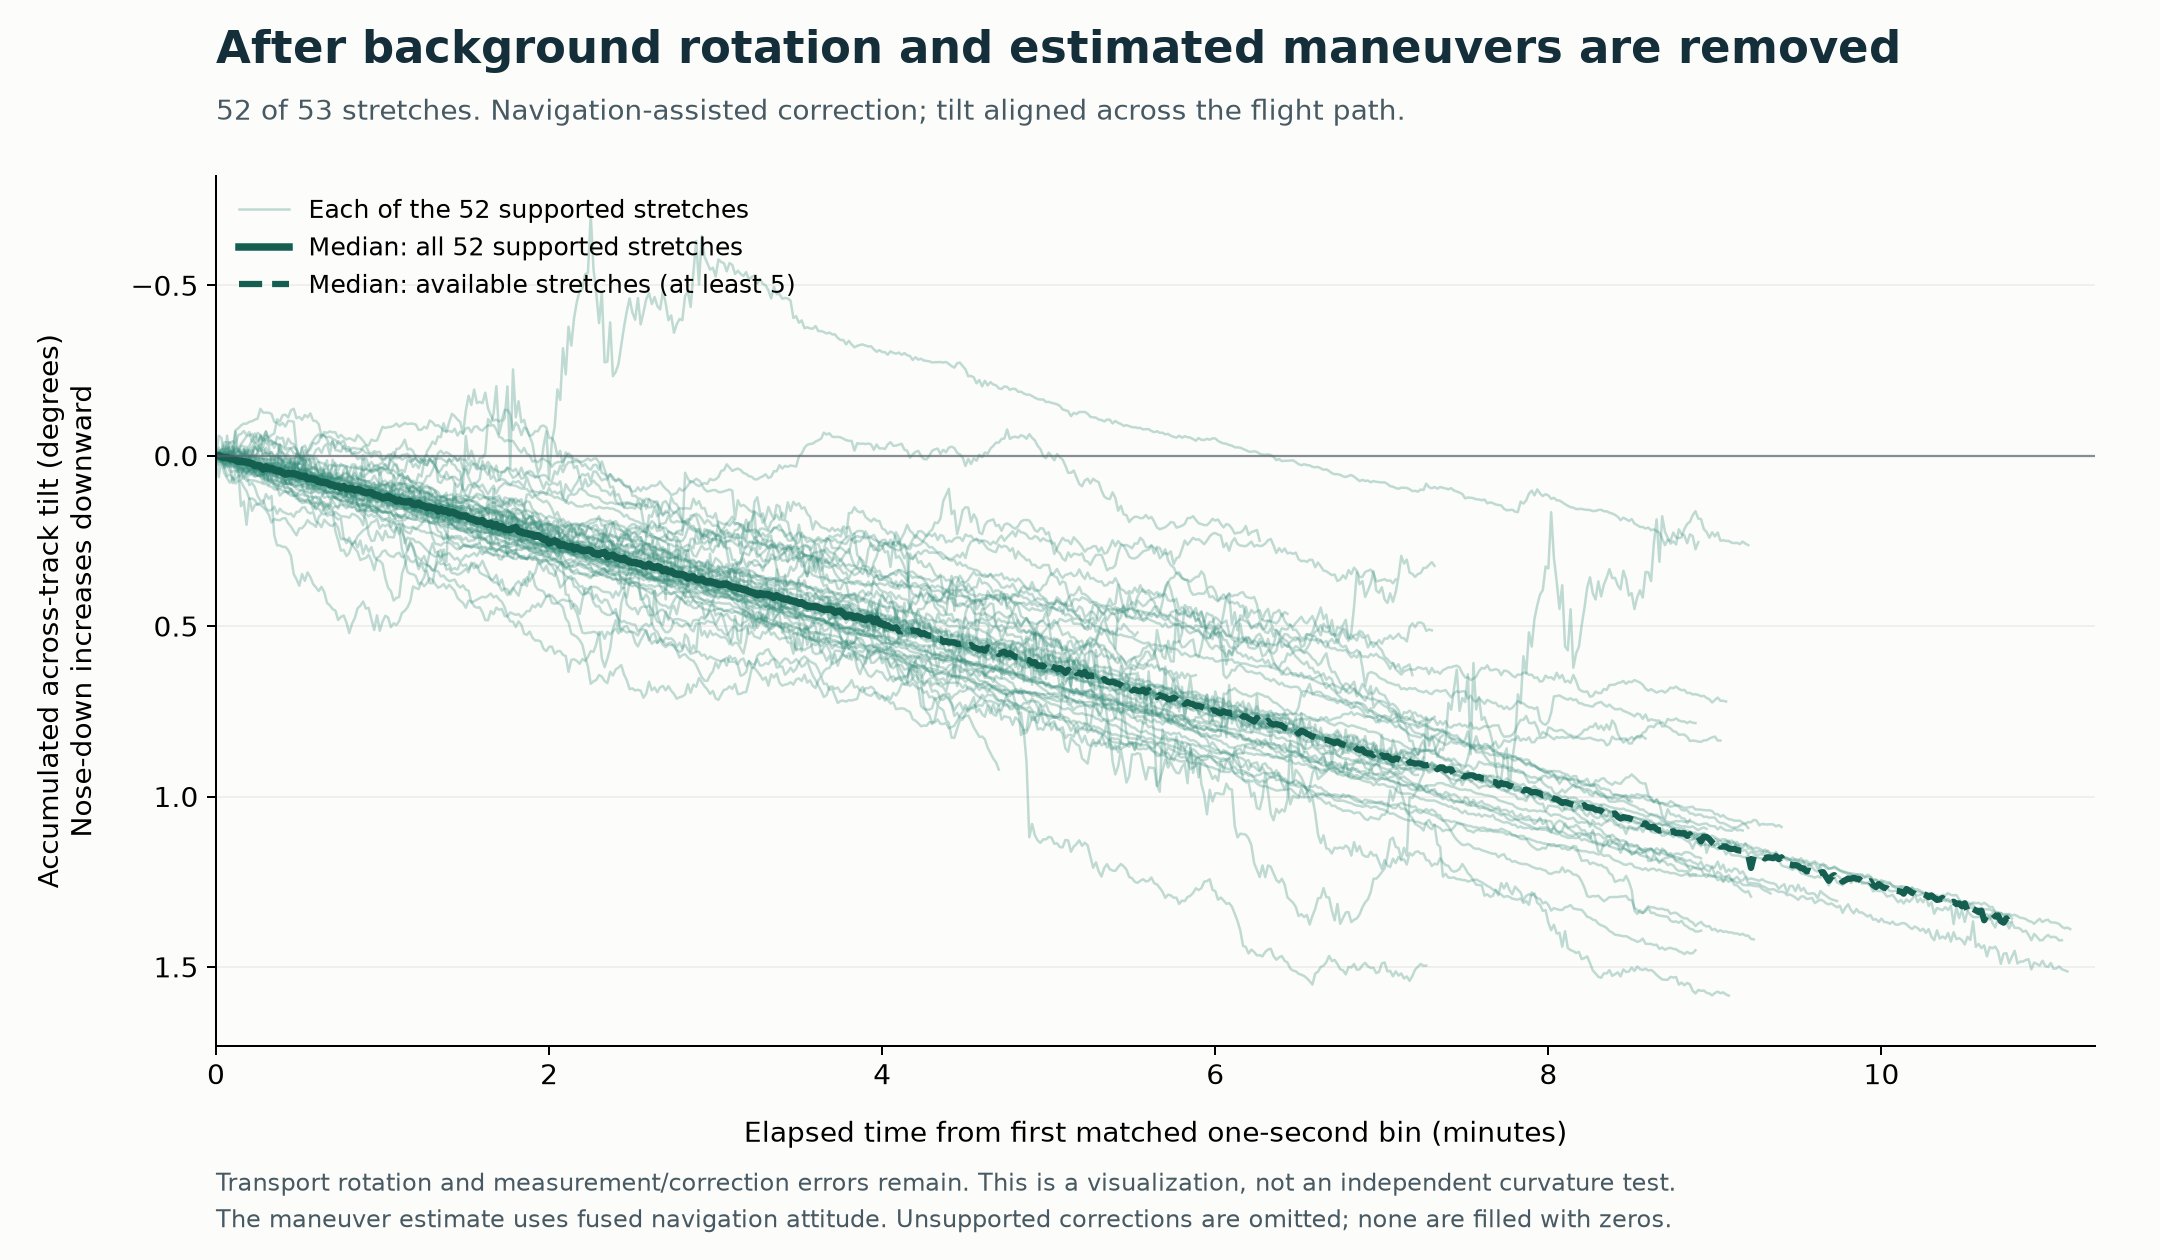
All 52 supported stretches finish nose-down. Their accumulated endpoints range from 0.25° to 1.58°, with a median of 0.92°. Stretches have different lengths; this endpoint median is not the angle at one common time.
What “aircraft motion” means here
An IMU (inertial measurement unit) records turning and specific force. Here, aircraft motion means changes in pitch, roll and heading relative to the local horizon, including their combined effect on the gyro axes. It does not include the turning of local level as the aircraft travels over a curved surface. That transport rotation is left in the graph.
The maneuver estimate comes from changes in the instrument's fused navigation attitude: its roll, pitch and heading. It uses no fused gyro-rate channels. After subtracting those estimated maneuvers from the recorded gyro vector, the display aligns the remaining tilt across the flight path and subtracts the specified background-field projection, using receiver latitude and course. The supplied field is approximately 15.04°/hour; its magnitude is not fitted. The calculation assumes that field was fully retained in the recorded increments.
This third graph uses an across-track axis. The first two use the aircraft-fixed pitch axis, so the three displays are closely related but do not show precisely the same component when heading and course differ.
Coverage and interpretation
The saved correction covers every matched bin in 52 stretches. One recording,
ILVIS0_applanix_57298_610_DMS_03Oct15DMS.013 (stretch
f50ff54d2e6175d2e8277823), has a usable cached correction for only 65 of its
547 matched seconds. Its entire trace is omitted rather than filling the missing
482 seconds. This is a limitation of the preserved correction, not a claim that
the original file lacks navigation attitude. All 53 outcomes remain in the
coverage table, and all 25,433 matched bins remain in the export.
The research selection and results are unchanged.
Thin lines show complete supported stretches. The solid median uses all 52; the dashed median uses the stretches still available, while at least five remain. The vertical scale matches the second, background-subtracted graph exactly.
This is a navigation-assisted visualization, not an independent curvature test. Fused attitude already depends on a navigation model. Transport rotation, instrument errors and errors in the maneuver estimate remain; the curve is not “pure curvature.” Overlapping recorders are not independent flights.
Raw graph · Background-only subtraction · Full-size image · Vector image · Per-bin values · Coverage and endpoints · Reproduction plan.


The builder checks preserved input hashes and reads saved descriptive measurements. It performs no new raw-file decoding, scientific fitting or model selection.