Joint Z-axis profile results
Completed 27 charged starts on one recording and one processing case. All failures remain recorded. IMU means inertial measurement unit. The fixed gain/offset grid tests calibration sensitivity, not instrument drift.
| Model | Gain (%) | Offset (degrees/hour) | Status | Achieved cost |
|---|---|---|---|---|
| sphere_rotating | -2 | -1 | converged | 5.61282 |
| sphere_still | -2 | -1 | converged | 9325.73 |
| flat_still | -2 | -1 | converged | 40624.4 |
| sphere_rotating | -2 | 0 | converged | 5.62023 |
| sphere_still | -2 | 0 | converged | 9454.42 |
| flat_still | -2 | 0 | converged | 40758 |
| sphere_rotating | -2 | 1 | converged | 5.62879 |
| sphere_still | -2 | 1 | converged | 9593.68 |
| flat_still | -2 | 1 | converged | 40858.5 |
| sphere_rotating | 0 | -1 | converged | 5.62074 |
| sphere_still | 0 | -1 | converged | 9354.12 |
| flat_still | 0 | -1 | converged | 40649.3 |
| sphere_rotating | 0 | 0 | converged | 5.6281 |
| sphere_still | 0 | 0 | converged | 9484.31 |
| flat_still | 0 | 0 | converged | 40780.1 |
| sphere_rotating | 0 | 1 | unresolved | 5.63637 |
| sphere_still | 0 | 1 | converged | 9622.43 |
| flat_still | 0 | 1 | converged | 40878.5 |
| sphere_rotating | 2 | -1 | converged | 5.62953 |
| sphere_still | 2 | -1 | converged | 9382.9 |
| flat_still | 2 | -1 | converged | 40673.1 |
| sphere_rotating | 2 | 0 | unresolved | 5.63628 |
| sphere_still | 2 | 0 | converged | 9514.24 |
| flat_still | 2 | 0 | converged | 40801.4 |
| sphere_rotating | 2 | 1 | converged | 5.64527 |
| sphere_still | 2 | 1 | converged | 9650.28 |
| flat_still | 2 | 1 | converged | 40897.5 |
Complete-grid shape preference: unresolved. Unfinished points give upper bounds on their unknown best fits; they do not complete a profile surface.
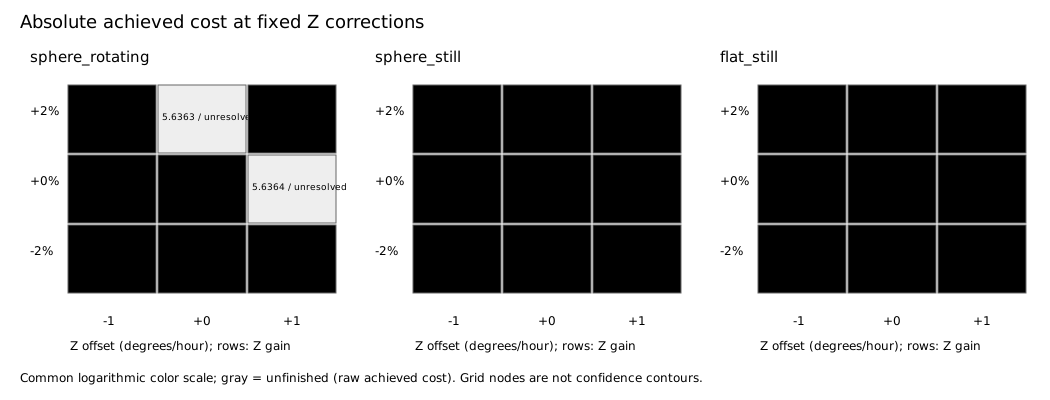
Figures show the nine grid nodes without interpolating unfinished points. Gray nodes retain raw achieved costs. The coarse grid cannot establish a global optimum or calibrated confidence region. Model names specify background fields, not their cause. This separate grid changes only its declared processing case or recording.
Preparation and reproduction instructions. All scientific decisions abstain.