Latitude and increment-convention controls
24/24 software fits passed the predefined numerical checks. This extends the original-rate comparison to +45° and −45° latitude. No NASA recordings were refitted. See the frozen plan.
An IMU (inertial measurement unit) records turning and acceleration. These controls use independently calculated motion and known calibration to test the software, rather than infer an Earth model from real measurements. Each model receives observations generated from its own physical truth. All tracks last 12 seconds at 220 m/s and 1,000 m.
Calibration recovery
The interior case uses pitch/yaw and regular timing. The near/roll case combines added roll, unequal timing and calibration close to its limits. Both run from zero and a deliberately opposed start, with the same original six-parameter bounds and solver. Pass criteria check convergence and position prediction; calibration error is separately reported and can expose weakness even when a fit passes. These noise-free short tracks do not qualify full archival nuisance freedom or uncertainty estimates.
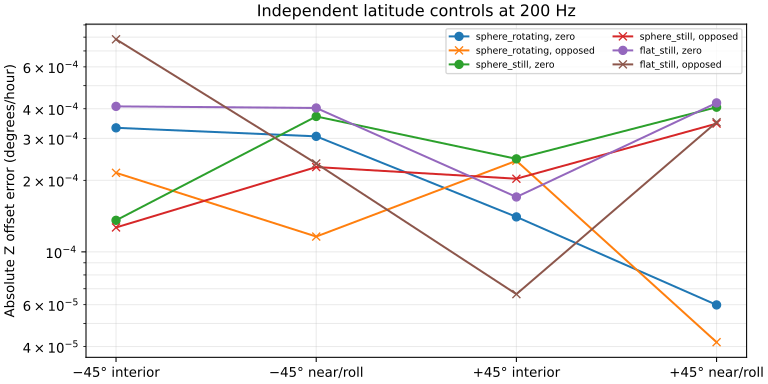
| Control identity: model / latitude / construction / start | Numerical pass | Z offset error (°/hour) | Maximum position error (m) |
|---|---|---|---|
| sphere_rotating::-45::interior::zero | yes | 0.00033241612060354536 | 8.695278573223765e-10 |
| sphere_rotating::-45::interior::opposed | yes | -0.00021503608624073744 | 7.170313476266573e-10 |
| sphere_rotating::-45::near_roll::zero | yes | -0.0003061295293195804 | 2.918199964622211e-09 |
| sphere_rotating::-45::near_roll::opposed | yes | 0.00011600998645740039 | 8.5933908101292e-10 |
| sphere_rotating::+45::interior::zero | yes | 0.0001403357498050899 | 5.716839490113878e-10 |
| sphere_rotating::+45::interior::opposed | yes | -0.00024167903774246363 | 9.115346256409082e-10 |
| sphere_rotating::+45::near_roll::zero | yes | 5.984025833653465e-05 | 6.817875984741058e-10 |
| sphere_rotating::+45::near_roll::opposed | yes | 4.17169305767744e-05 | 6.327287815071813e-10 |
| sphere_still::-45::interior::zero | yes | 0.00013576341815423079 | 6.520234242794834e-10 |
| sphere_still::-45::interior::opposed | yes | -0.00012669970092617095 | 5.768276349279427e-10 |
| sphere_still::-45::near_roll::zero | yes | -0.00037117033563245866 | 2.984914791637915e-09 |
| sphere_still::-45::near_roll::opposed | yes | 0.0002273953753818805 | 1.403568358833388e-09 |
| sphere_still::+45::interior::zero | yes | 0.00024615226357556065 | 9.22763475699816e-10 |
| sphere_still::+45::interior::opposed | yes | -0.00020310193465824158 | 7.44119895928276e-10 |
| sphere_still::+45::near_roll::zero | yes | -0.0004059109326854813 | 3.3120312798658384e-09 |
| sphere_still::+45::near_roll::opposed | yes | -0.0003463110468685448 | 2.975548278857464e-09 |
| flat_still::-45::interior::zero | yes | 0.00040916737106576557 | 1.988027948751934e-09 |
| flat_still::-45::interior::opposed | yes | -0.0007833450216308053 | 2.6398537313758797e-09 |
| flat_still::-45::near_roll::zero | yes | -0.0004028607236836542 | 3.2029920051054275e-09 |
| flat_still::-45::near_roll::opposed | yes | -0.00023538333640778952 | 2.278427855642444e-09 |
| flat_still::+45::interior::zero | yes | 0.00017018081292698755 | 1.0841977875955902e-09 |
| flat_still::+45::interior::opposed | yes | 6.64312989094944e-05 | 2.1639368210081254e-10 |
| flat_still::+45::near_roll::zero | yes | -0.0004232350705416418 | 3.381307270667418e-09 |
| flat_still::+45::near_roll::opposed | yes | -0.00035100913922548466 | 3.0391921347189644e-09 |
Why the increment convention matters
The additional controls define already-compensated increments from exact attitude endpoints and an independently integrated force. Receiver observations occur at packet endpoints. The second column of errors deliberately mislabels these measurements as ordinary integrated rates, so the candidate applies an inappropriate second correction. Correctly labelled inputs are rejected by the enabled correction's guard.
| Supplied truth | Latitude | Appropriate original treatment: error (m) | Deliberate double correction: error (m) |
|---|---|---|---|
| sphere_rotating | -45° | 0.0 | 4.144646863046123e-05 |
| sphere_rotating | +45° | 0.0 | 4.1529090367724386e-05 |
| sphere_still | -45° | 0.0 | 4.1574526940765726e-05 |
| sphere_still | +45° | 0.0 | 4.159019531024272e-05 |
| flat_still | -45° | 0.0 | 4.161536212986764e-05 |
| flat_still | +45° | 0.0 | 4.162371511561573e-05 |
This mathematical convention is precisely defined for this control. It is not a claim about Applanix firmware. Partial-packet finite increments need their own convention; these endpoint checks do not qualify arbitrary interpolation. Neither correction path can be assigned to the NASA archive solely because one wins on a software control.
Reproducibility and limits
The run charged 24 fit starts and 36 known-calibration predictions, using 1042 native sweeps within the 4,836-sweep ceiling, with no retries. See fit details and known-calibration checks. Sources, environment, compiler and native binary are hashed; interrupted starts remain charged. The archive's scientific evidence gate is unchanged.
Publication reads saved results and starts no fits:
env PYTHONPATH=analysis MPLCONFIGDIR=/tmp/lll-latitude-matplotlib ~/venv/bin/python docs/ilvis0-latitude-controls-20261011/build_report.py --package-only